
Built on a unified high-fidelity foundation, AperOne integrates core capabilities including Vision-Language-Action (VLA) models and world models. It spans the full workflow of data acquisition, scene reconstruction, model training, simulation evaluation, physical deployment and operational feedback, forming a closed Real2Sim2Real loop and serving as a core embodied intelligence hub that supports scenario adaptation, collaborative operation and continuous evolution for multi-brand, multi-form-factor robots.

核心优势
Safer: Proactive Risk Validation
Validate robot perception, decision-making and execution strategies in a high-fidelity physics-based digital twin via long-tail and extreme-condition data, cutting real-world trial costs and on-site operational risks.
More Efficient: Accelerated Scenario Deployment
Complete embodied task orchestration, policy training, simulation evaluation and scenario adaptation in virtual training grounds, enabling one-click deployment to physical robots.
More Controllable: Full-Process Online Operation
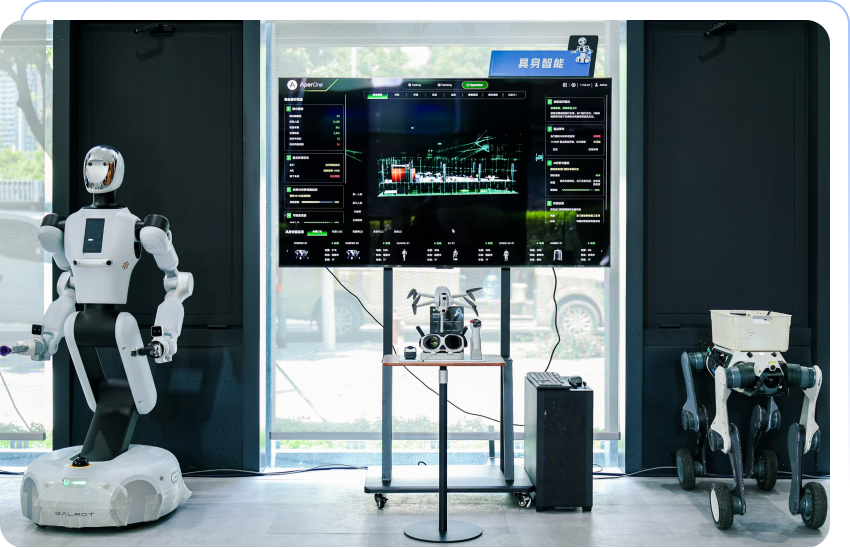
Unify management of multi-brand, multi-form robots with real-time status, task progress and alerts, supporting multi-robot collaborative scheduling and closed-loop operations.
Smarter: Continuous Capability Evolution
Feed back real-world multimodal data and task outcomes to drive model and policy iteration, forming a sustainable Real2Sim2Real evolution loop.
More Open: Diverse Ecosystem Compatibility
Standard interfaces connect heterogeneous robot hardware,VLAs, world models, and third-party simulation engines and algorithms, supporting rapid integration and flexible expansion of embodied intelligence applications.
Three Major Modules, Covering the Full Process of Embodied Implementation

Testing
Competing on the same stage within real twin scenes, offering a unified procurement simulation benchmark evaluation system to provide reproducible and quantifiable horizontal evaluations for different robot hardware and algorithms.
- Horizontal comparison of multiple hardware types in the same scene
- Reproducible benchmarks for procurement selection

Training
Infinite preview and synthesis of long-tail failure scenarios, driving the self-evolution of embodied large models within high-fidelity twin environments to complete training and iteration before entering the physical site.
- Batch generation of long-tail / hazardous operating conditions
- Self-evolution of strategies within twin environments

Operations
Global assets managed via a single screen, featuring a complete closed loop of collision avoidance, intelligent scheduling, and work orders to eliminate "mobile information silos" and achieve system-level collaboration.
- Full-time monitoring and intelligent scheduling
- Collision avoidance + closed-loop work orders
Embodied Intelligence Full-Stack Product Matrix

AES
Embodied Intelligence Real2Sim Scene Reconstruction, providing a high-rendering, fully semantic, and omni-spatiotemporal digital twin spatial intelligence foundation.

AperData
Embodied Intelligence Synthetic Data Pipeline, providing a continuous stream of high-quality data and generalization fuel for embodied training.

AperOne
Embodied Intelligence Application Closed-Loop System, integrating perceptual reconstruction, model training, simulation evaluation, operational supervision, and data feedback to facilitate the large-scale deployment of robots.
Full-Link Closed Loop, Empowering Application Implementation

Typical
Application Scenarios
Typical Application Scenarios


Campus Inspection
HotTargeting campus roads, building facades, underground passages, and key points to support autonomous cruising, anomaly recognition, and multi-machine coordinated scheduling for inspection robots.

Mines & Underground Mine Shafts
HotSimulating and previewing major safety accidents during high-risk stages such as excavation, inspection, and rescue to ensure ready-to-use, stable, and reliable deployment upon arrival.

Smart Agriculture
Agricultural machinery HIL (Hardware-in-the-Loop) simulation and parametric scene generation to solve challenges like high field collection costs, significant seasonal variations, and numerous long-tail operating conditions.

Digital Factory
Production line cyber-physical mapping and real-time synchronization, accurately tracing material flows and predicting equipment failures.

Low-Altitude Economy
Perception and decision-making deduction within complex airspace, executing low-cost, high-concurrency drills for long-tail risks.

Emergency Management & Disaster Prevention
Repeated previews of high-risk scenarios, transforming uncontrollable verifications into controllable, reproducible, and iterable ones.